Jingyuan Liu

Embodied AI & Robot Learning

Hi there! I’m Jingyuan, currently an undergraduate student at Fudan University. I work on vision-language-action models, reward modeling and reinforcement learning for robotics, world models for manipulation, and continual, self-improving robot learning. My long-term vision is to develop general-purpose and trustworthy robots that can perform a wide range of everyday tasks, continually adapt in new environments, and operate reliably and safely in the real world.

Outside of research, I’m also a big fan of football and baseball!

Publications & Manuscripts

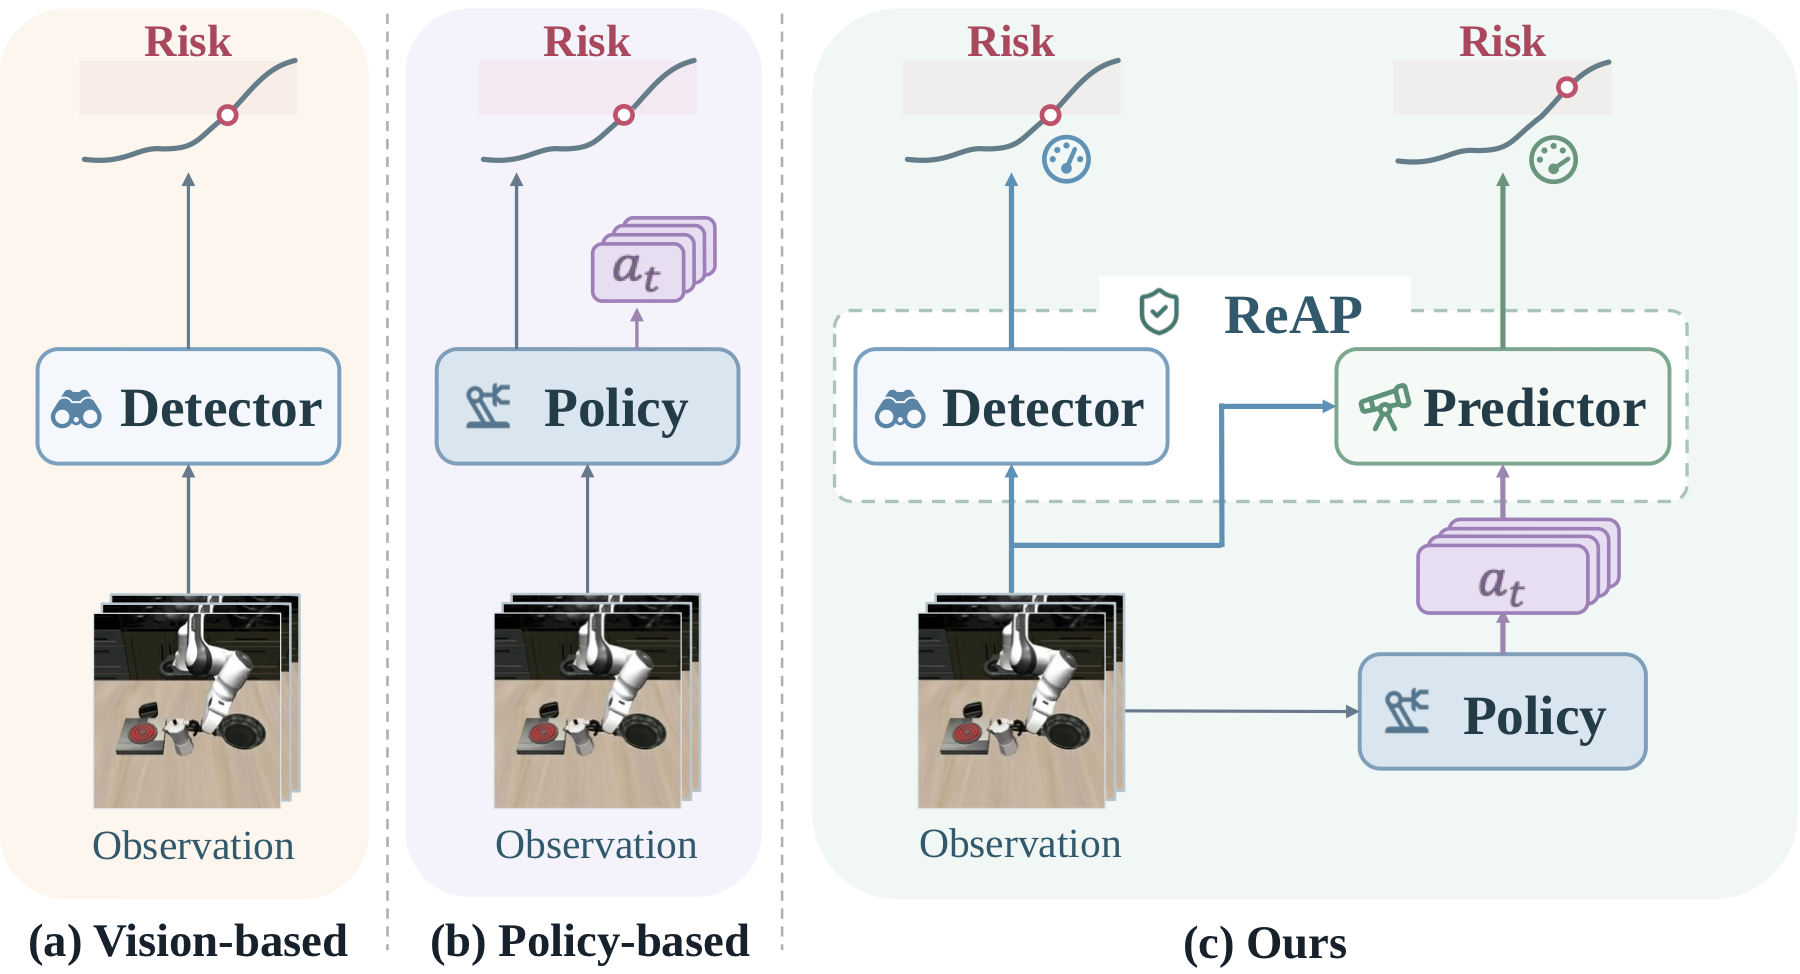
ReAP combines visual failure detection with action-conditioned future-risk prediction for runtime robot monitoring.

ReAP: From Visual Failure Recognition to Action-Conditioned Risk Prediction for Runtime Failure Monitoring

Jingyuan Liu, Yunpeng Qing, Changxu Wei, Zhi Hou

Under review at ICLR 2027

ReAP is a policy-decoupled runtime monitoring framework that combines visual failure detection with action-conditioned future-risk prediction in a failure-relevant latent space.
Ongoing Projects

Ongoing research

Action Prediction via Wrist-Camera Motion

Predicting robot actions as future wrist-camera poses, using changes in camera position and orientation to represent robot motion for manipulation.